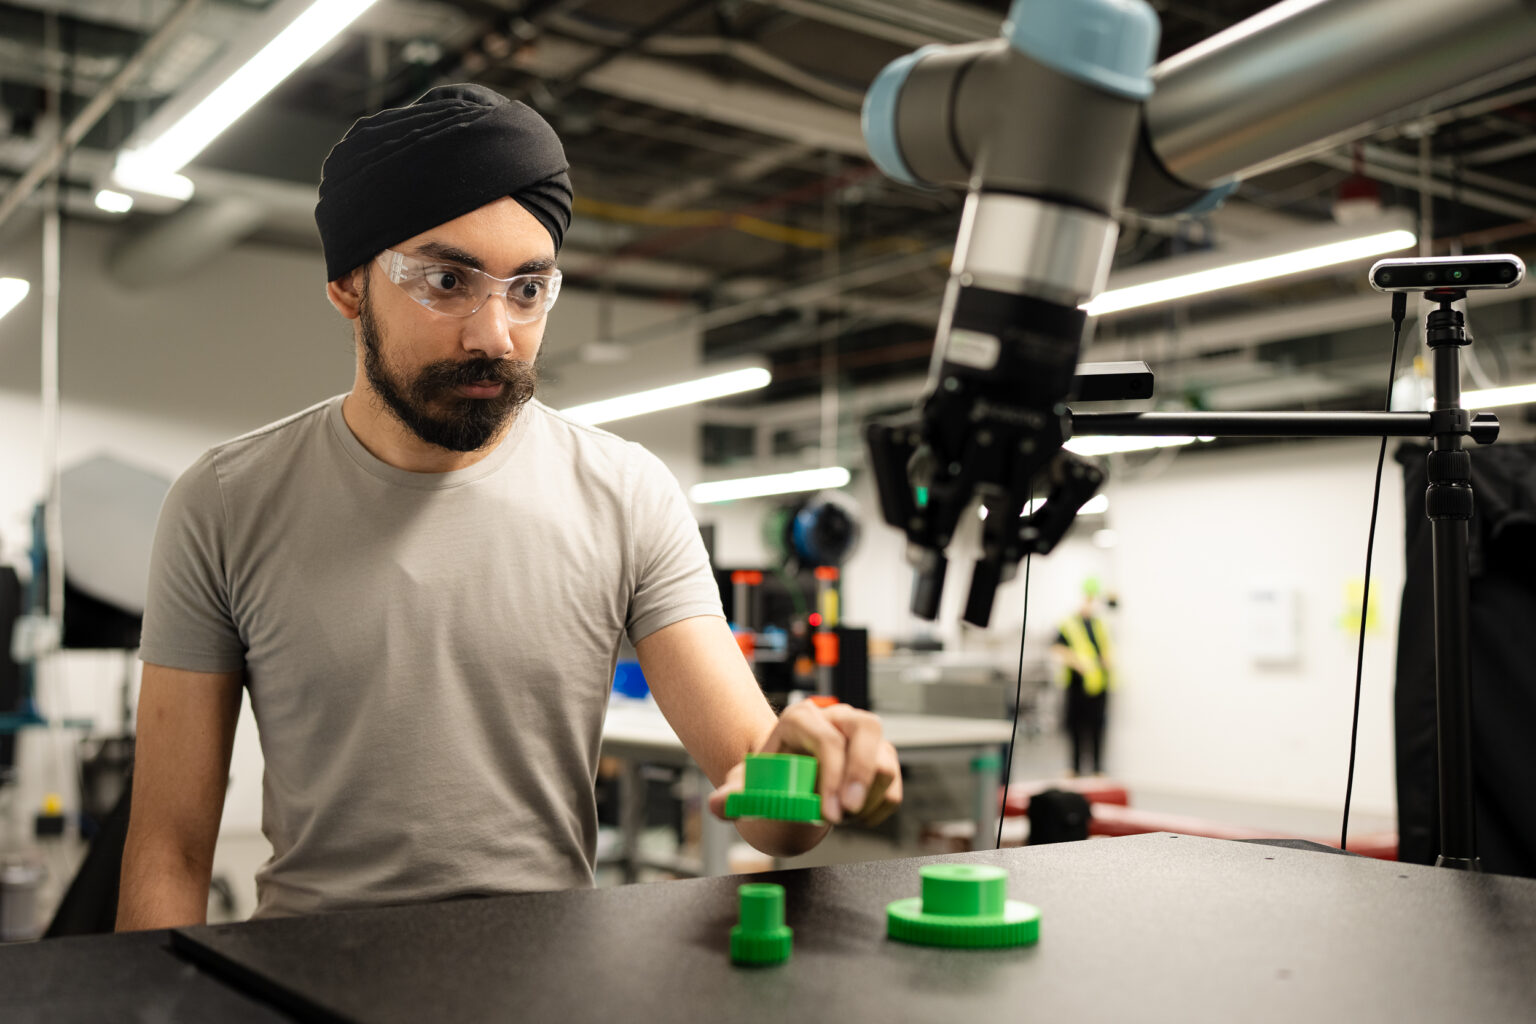
<p>NVIDIA’s Robotics page references a June 30, 2026 publication that places Isaac ROS at the practical center of its robotics software stack. Built on open-source ROS 2, the framework gives developers CUDA-accelerated libraries and AI models for autonomous mobile robots, manipulation systems and humanoids. For teams working on field robots, the important question is how much existing ROS software can carry from a prototype into a deployed machine.</p><h2>What developers get</h2><p>According to <a href="https://blogs.nvidia.com/blog/nvidia-life-jaiveer-singh">NVIDIA’s overview of Isaac ROS</a>, its packages cover perception, object detection, mapping, collision detection and motion planning. The packages are modular and can be combined with existing ROS code, giving teams a way to add accelerated components without discarding an established ROS 2 architecture. That modularity can reduce software rework, but it does not guarantee that every sensor, controller or safety configuration will transfer unchanged between robots.</p><h2>Compatibility across the compute layer</h2><p>Isaac ROS can run on workstations, NVIDIA DGX Spark personal supercomputers and NVIDIA Jetson edge systems. NVIDIA has also described direct contributions to ROS 2 through GPU-aware abstractions that can manage central processors, integrated GPUs and discrete GPUs. For developers, that creates a route from heavier development hardware to an edge deployment target, while the actual compute choice remains part of the robot’s design and validation work.</p><h2>Simulation and safety are part of the story</h2><p>In an <a href="https://blogs.nvidia.com/blog/roscon-2025-open-framework-robotics">October 26, 2025 ROSCon update</a>, NVIDIA presented Isaac ROS 4.0 as a collection of GPU-accelerated libraries and AI models compatible with ROS, available on the Jetson Thor platform. NVIDIA and Robotec.ai were also integrating a ROS simulation standard into Isaac Sim for inter-simulator development and automated testing. That gives teams a more repeatable way to develop and test robot behavior before deployment. Simulation remains a development layer, though; it is not evidence that a particular robot is safe in every real-world site.</p><h2>What changes at deployment</h2><p>The <a href="https://blogs.nvidia.com/blog/nvidia-isaac-nova-orin">Nova Orin platform</a> adds secure over-the-air updates, device management and supervision. One reference architecture includes functionally safety-certified sensors and a safety programmable logic controller. NVIDIA also says it is working with regulatory bodies on vision-based safety technology for autonomous mobile robots, while Nova Orin can be integrated into ROS-based robotics applications.</p><p>Those pieces address different parts of the deployment problem: ROS 2 compatibility supports software reuse, Isaac ROS targets perception and motion, simulation supports repeatable testing, and Nova Orin adds operational and safety-oriented controls. They do not amount to blanket regulatory approval for every robot or deployment. The final safety and compliance work still depends on the machine, its operating environment and the relevant authorities.</p><p>Isaac ROS matters because it connects a familiar ROS 2 base to accelerated robotics functions across workstation, DGX Spark and Jetson targets. The trade-off is clear: a modular developer stack can make adaptation easier, but it does not remove the hardware, validation and regulatory work required by each field deployment. NVIDIA’s June 2026 material presents a platform path for robot developers, not a turnkey deployment guarantee.</p><section class="media-fleet-sources"><h2>Official sources</h2><ul><li><a href="https://blogs.nvidia.com/blog/category/robotics">Official source: blogs.nvidia.com</a></li><li><a href="https://blogs.nvidia.com/blog/nvidia-life-jaiveer-singh">Official source: blogs.nvidia.com</a></li><li><a href="https://blogs.nvidia.com/blog/roscon-2025-open-framework-robotics">Official source: blogs.nvidia.com</a></li><li><a href="https://blogs.nvidia.com/blog/nvidia-isaac-nova-orin">Official source: blogs.nvidia.com</a></li></ul></section><aside class="media-fleet-related"><h2>Related reading</h2><ul><li><a href="https://rentbuyrobot.com/article/hirebotics-paint-cobot-deployment-scope-safety-limits">Hirebotics Paint Cobot Deployment Scope Safety Limits</a></li><li><a href="https://rentbuyrobot.com/article/nvidia-toyota-simulation-first-robot-deployment">Nvidia Toyota Simulation First Robot Deployment</a></li></ul></aside>
PrototypeReport
NVIDIA Isaac ROS links ROS 2 tools to field robot development
NVIDIA’s June 30, 2026 robotics material explains where Isaac ROS fits in a ROS 2 stack, from accelerated perception and simulation to edge deployment and safety.